
About Me
I am a postdoctoral researcher at the ICON Lab at UC Berkeley, where I work with Negar Mehr. I obtained my PhD from TU Delft, where I was advised by Javier Alonso-Mora and Laura Ferranti. Beyond Berkeley and Delft, I worked with Cyrill Stachniss at the University of Bonn and as a visiting researcher with Andrea Bajcsy at Carnegie Mellon University.
I develop algorithms that let robots handle complex interaction with the real world. That complexity may come from challenging dynamics, as in agile flight or contact-rich manipulation, or from other agents, humans and robots alike, whose behavior the robot must anticipate. My work builds on tools from reinforcement learning, imitation learning, and game theory to make such interaction tractable: learning policies and interaction models from limited data and keeping robots safe when their models are uncertain. I care about methods that work on real hardware, so I validate them on manipulators, mobile robots, and quadrotors.
My dissertation focused on the multi-agent side of this picture: using dynamic game theory to capture how a robot’s decisions and those of the agents around it shape each other. My RSS Pioneers research statement provides a more detailed overview of my past work and future directions.
Contact
For coordinating meetings, this calendar shows times when I will be busy.
Email: lasse.peters@berkeley.edu
Selected Publications
-
Coordinated Diffusion: Generating Multi-Agent Behavior Without Multi-Agent Demonstrations Hardware · Frankapaperwebsite
bib
@article{peters2026codi, title = {Coordinated Diffusion: Generating Multi-Agent Behavior Without Multi-Agent Demonstrations}, author = {Peters, Lasse and Ferranti, Laura and Bajcsy, Andrea and Alonso-Mora, Javier}, journal = {arXiv preprint arXiv:2605.11485}, year = {2026}, url = {https://arxiv.org/abs/2605.11485} } -
Strategizing at Speed: A Learned Model Predictive Game for Multi-Agent Drone Racing Hardware · Agilicious quadrotorpaper
bib
@article{papuc2026strategizing, title = {Strategizing at Speed: A Learned Model Predictive Game for Multi-Agent Drone Racing}, author = {Papuc, Andrei-Carlo and Peters, Lasse and Sun, Sihao and Ferranti, Laura and Alonso-Mora, Javier}, journal = {IEEE Robotics and Automation Letters (RA-L)}, volume = {11}, number = {8}, pages = {9056--9063}, year = {2026}, doi = {10.1109/LRA.2026.3701568} } -
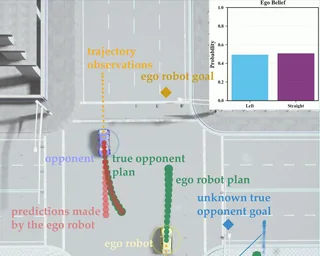
Bayesian Inverse Games with High-Dimensional Multi-Modal Observationspaper
bib
@article{jain2026bayesian, title = {Bayesian Inverse Games with High-Dimensional Multi-Modal Observations}, author = {Jain, Yash and Liu, Xinjie and Peters, Lasse and Fridovich-Keil, David and Topcu, Ufuk}, journal = {arXiv preprint arXiv:2601.00696}, year = {2026}, url = {https://arxiv.org/abs/2601.00696} } -
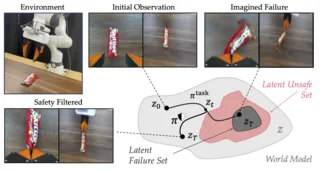
Generalizing Safety Beyond Collision-Avoidance via Latent-Space Reachability Analysis Hardware · Frankapaperwebsite
bib
@inproceedings{nakamura2025latent, title = {Generalizing Safety Beyond Collision-Avoidance via Latent-Space Reachability Analysis}, author = {Nakamura, Kensuke and Peters, Lasse and Bajcsy, Andrea}, booktitle = {Proc.~of Robotics: Science and Systems (RSS)}, year = {2025}, doi = {10.15607/RSS.2025.XXI.113} } -
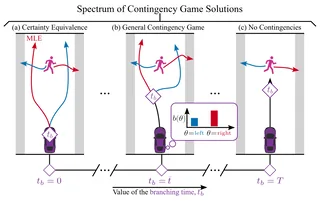
Contingency Games for Multi-Agent Interactionpaperwebsitecodevideo
bib
@article{peters2024ral, title={Contingency Games for Multi-Agent Interaction}, author={Peters, Lasse and Bajcsy, Andrea and Chiu, Chih-Yuan and Fridovich-Keil, David and Laine, Forrest and Ferranti, Laura and Alonso-Mora, Javier}, journal={IEEE Robotics and Automation Letters (RA-L)}, year={2024}, volume={9}, number={3}, pages={2208--2215}, doi={10.1109/lra.2024.3354548}, } -
Learning Mixed Strategies in Trajectory Gamespaperwebsitecodevideo
bib
@inproceedings{peters2022rss,
    title     = {Learning Mixed Strategies in Trajectory Games},
    author    = {Peters, Lasse and Fridovich-Keil, David and Ferranti, Laura and Stachniss, Cyrill and Alonso-Mora, Javier and Laine, Forrest},
    booktitle = {Proc.~of Robotics: Science and Systems (RSS)},
    year      = {2022},
    url       = {https://arxiv.org/abs/2205.00291},
    doi       = {10.15607/rss.2022.xviii.051},
}
* Equal contribution† Equal advising