Publications
Preprints
-
Coordinated Diffusion: Generating Multi-Agent Behavior Without Multi-Agent Demonstrations Hardware · Frankapaperwebsite
bib
@article{peters2026codi, title = {Coordinated Diffusion: Generating Multi-Agent Behavior Without Multi-Agent Demonstrations}, author = {Peters, Lasse and Ferranti, Laura and Bajcsy, Andrea and Alonso-Mora, Javier}, journal = {arXiv preprint arXiv:2605.11485}, year = {2026}, url = {https://arxiv.org/abs/2605.11485} } -
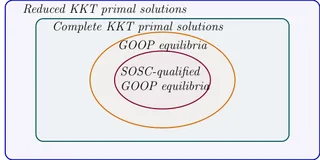
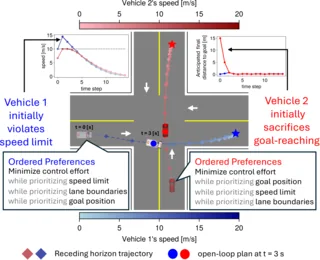
Breaking Exponential Complexity in Games of Ordered Preference: A Tractable Reformulationpaper
bib
@article{lee2026breaking, title = {Breaking Exponential Complexity in Games of Ordered Preference: A Tractable Reformulation}, author = {Lee, Dong Ho and Li, Jingqi and Peters, Lasse and Bakirtzis, Georgios and Fridovich-Keil, David}, journal = {arXiv preprint arXiv:2603.26950}, year = {2026}, url = {https://arxiv.org/abs/2603.26950} } -
Bayesian Inverse Games with High-Dimensional Multi-Modal Observationspaper
bib
@article{jain2026bayesian,
    title   = {Bayesian Inverse Games with High-Dimensional Multi-Modal Observations},
    author  = {Jain, Yash and Liu, Xinjie and Peters, Lasse and Fridovich-Keil, David and Topcu, Ufuk},
    journal = {arXiv preprint arXiv:2601.00696},
    year    = {2026},
    url     = {https://arxiv.org/abs/2601.00696}
}
Journal
-
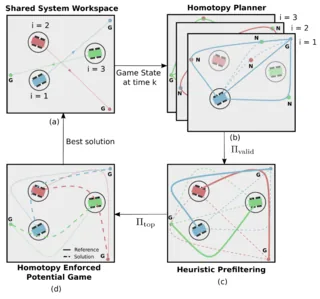
Homotopy-Guided Potential Games for Congestion-Aware Navigation Hardware · Clearpath Jackalpaper
bib
@article{imran2026homotopy, title = {Homotopy-Guided Potential Games for Congestion-Aware Navigation}, author = {Imran, Mohammed Irshadh Ismaaeel Sathyamangalam and Peters, Lasse and Khayyat, Michael and Arrigoni, Stefano and Braghin, Francesco and Ferranti, Laura}, journal = {IEEE Robotics and Automation Letters (RA-L)}, year = {2026}, doi = {10.1109/LRA.2026.3675907}, pages = {5962--5969}, volume = {11}, number = {5}, } -
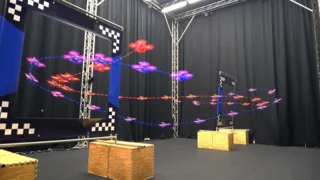
Strategizing at Speed: A Learned Model Predictive Game for Multi-Agent Drone Racing Hardware · Agilicious quadrotorpaper
bib
@article{papuc2026strategizing, title = {Strategizing at Speed: A Learned Model Predictive Game for Multi-Agent Drone Racing}, author = {Papuc, Andrei-Carlo and Peters, Lasse and Sun, Sihao and Ferranti, Laura and Alonso-Mora, Javier}, journal = {IEEE Robotics and Automation Letters (RA-L)}, volume = {11}, number = {8}, pages = {9056--9063}, year = {2026}, doi = {10.1109/LRA.2026.3701568} } -
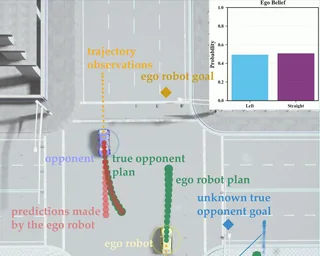
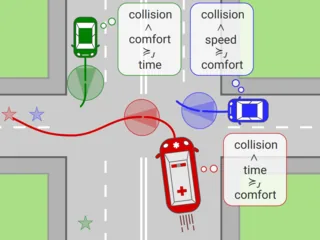
You Can't Always Get What You Want: Games of Ordered Preferencepaper
bib
@article{lee2025ordered, title = {You Can't Always Get What You Want: Games of Ordered Preference}, author = {Lee, Dong Ho and Peters, Lasse and Fridovich-Keil, David}, journal = {IEEE Robotics and Automation Letters (RA-L)}, year = {2025}, url = {https://ieeexplore.ieee.org/abstract/document/11018386/}, doi = {10.1109/lra.2025.3575324}, pages = {7182--7189}, volume = {10}, number = {7}, } -
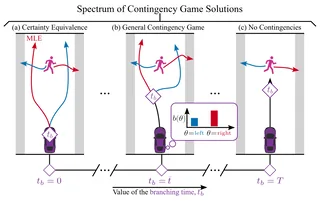
Contingency Games for Multi-Agent Interactionpaperwebsitecodevideo
bib
@article{peters2024ral, title={Contingency Games for Multi-Agent Interaction}, author={Peters, Lasse and Bajcsy, Andrea and Chiu, Chih-Yuan and Fridovich-Keil, David and Laine, Forrest and Ferranti, Laura and Alonso-Mora, Javier}, journal={IEEE Robotics and Automation Letters (RA-L)}, year={2024}, volume={9}, number={3}, pages={2208--2215}, doi={10.1109/lra.2024.3354548}, } -
Online and Offline Learning of Player Objectives from Partial Observations in Dynamic Gamespaperwebsitecode
bib
@inproceedings{peters2023ijrr, title = {Online and Offline Learning of Player Objectives from Partial Observations in Dynamic Games}, author = {Peters, Lasse and Rubies-Royo, Vicenc and Tomlin, Claire J. and Ferranti, Laura and Alonso-Mora, Javier and Stachniss, Cyrill and Fridovich-Keil, David}, booktitle = {Intl.~Journal~of Robotics Research (IJRR)}, year = {2023}, url = {https://journals.sagepub.com/doi/pdf/10.1177/02783649231182453}, doi = {10.1177/02783649231182453}, pages = {917--937}, volume = {42}, number = {10}, } -
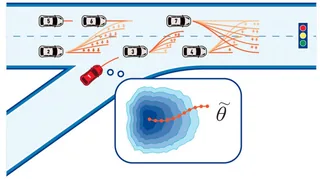
Learning to Play Trajectory Games Against Opponents with Unknown Objectives Hardware · Clearpath Jackalpaperwebsite
bib
@article{liu2023ral,
    title   = {Learning to Play Trajectory Games Against Opponents with Unknown Objectives},
    author  = {Liu, Xinjie and Peters, Lasse and Alonso-Mora, Javier},
    journal = {IEEE Robotics and Automation Letters (RA-L)},
    year    = {2023},
    url     = {https://ieeexplore.ieee.org/document/10137879},
    doi     = {10.1109/lra.2023.3280809},
    pages   = {4139--4146},
    volume  = {8},
    number  = {7},
}
Conference
-
Controllability in Preference-Conditioned Multi-Objective Reinforcement Learningpaper
bib
@inproceedings{molins2026controllability, title = {Controllability in Preference-Conditioned Multi-Objective Reinforcement Learning}, author = {de las Heras Molins, Pau and Yalcinkaya, Beyazit and Peters, Lasse and Fridovich-Keil, David and Bakirtzis, Georgios}, booktitle = {Proceedings of the International Conference on Neuro-symbolic Systems}, series = {Proceedings of Machine Learning Research}, publisher = {PMLR}, year = {2026}, note = {arXiv:2605.10585} } -
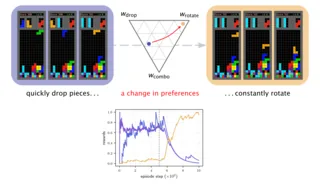
Approximate Solutions to Games of Ordered Preferencepaper
bib
@inproceedings{molins2025approximate, title = {Approximate Solutions to Games of Ordered Preference}, author = {de las Heras Molins, Pau and Roy-Almonacid, Eric and Lee, Dong Ho and Peters, Lasse and Fridovich-Keil, David and Bakirtzis, Georgios}, booktitle = {IEEE 28th International Conference on Intelligent Transportation Systems (ITSC)}, year = {2025}, url = {https://arxiv.org/abs/2507.11021}, doi = {10.1109/itsc60802.2025.11423775}, pages = {3378--3385}, } -
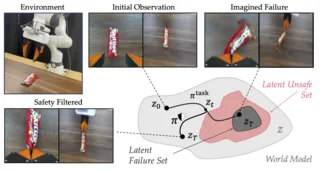
Generalizing Safety Beyond Collision-Avoidance via Latent-Space Reachability Analysis Hardware · Frankapaperwebsite
bib
@inproceedings{nakamura2025latent, title = {Generalizing Safety Beyond Collision-Avoidance via Latent-Space Reachability Analysis}, author = {Nakamura, Kensuke and Peters, Lasse and Bajcsy, Andrea}, booktitle = {Proc.~of Robotics: Science and Systems (RSS)}, year = {2025}, doi = {10.15607/RSS.2025.XXI.113} } -
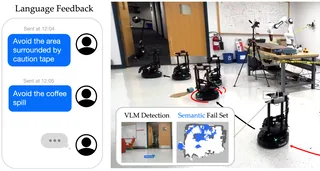
Updating Robot Safety Representations Online from Natural Language Feedback Hardware · LoCoBotpaperwebsite
bib
@inproceedings{santos2025updating, title = {Updating Robot Safety Representations Online from Natural Language Feedback}, author = {Santos, Leonardo and Li, Zirui and Peters, Lasse and Bansal, Somil and Bajcsy, Andrea}, booktitle = {IEEE International Conference on Robotics and Automation (ICRA)}, year = {2025}, url = {https://arxiv.org/abs/2409.14580}, doi = {10.1109/icra55743.2025.11127680}, pages = {7778--7785}, } -
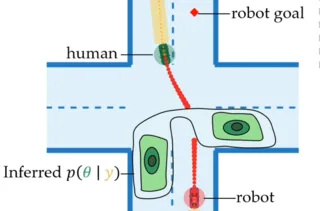
Auto-Encoding Bayesian Inverse Gamespaper
bib
@inproceedings{liu2024autoencoding, title = {Auto-Encoding Bayesian Inverse Games}, author = {Liu, Xinjie and Peters, Lasse and Alonso-Mora, Javier and Topcu, Ufuk and Fridovich-Keil, David}, booktitle = {International Workshop on the Algorithmic Foundations of Robotics (WAFR)}, year = {2024}, url = {https://arxiv.org/abs/2402.08902}, doi = {10.1007/978-3-032-09967-9_16}, pages = {311--331}, } -
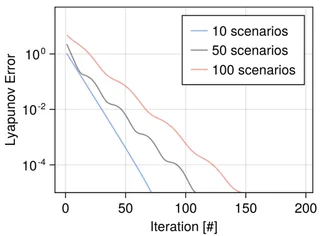
Scenario-Game ADMM: A Parallelized Scenario-Based Solver for Stochastic Noncooperative Gamespaper
bib
@inproceedings{li2023scenario, title = {Scenario-Game ADMM: A Parallelized Scenario-Based Solver for Stochastic Noncooperative Games}, author = {Li, Jingqi and Chiu, Chih-Yuan and Peters, Lasse and Palafox, Fernando and Karabag, Mustafa and Alonso-Mora, Javier and Sojoudi, Somayeh and Tomlin, Claire and Fridovich-Keil, David}, booktitle = {IEEE Conference on Decision and Control (CDC)}, year = {2023}, url = {https://arxiv.org/abs/2304.01945}, doi = {10.1109/cdc49753.2023.10383423}, pages = {8093--8099}, } -
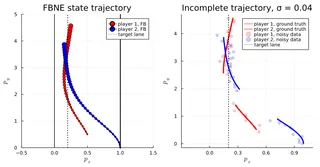
Cost Inference for Feedback Dynamic Games from Noisy Partial State Observations and Incomplete Trajectoriespaper
bib
@inproceedings{li2023cost, title = {Cost Inference for Feedback Dynamic Games from Noisy Partial State Observations and Incomplete Trajectories}, author = {Li, Jingqi and Chiu, Chih-Yuan and Peters, Lasse and Sojoudi, Somayeh and Tomlin, Claire and Fridovich-Keil, David}, booktitle = {International Conference on Autonomous Agents and Multiagent Systems (AAMAS)}, year = {2023}, url = {https://arxiv.org/abs/2301.01398}, doi = {10.65109/ayet2783}, } -
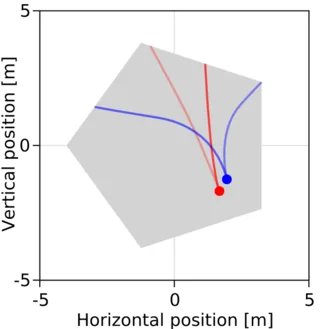
Learning Mixed Strategies in Trajectory Gamespaperwebsitecodevideo
bib
@inproceedings{peters2022rss, title = {Learning Mixed Strategies in Trajectory Games}, author = {Peters, Lasse and Fridovich-Keil, David and Ferranti, Laura and Stachniss, Cyrill and Alonso-Mora, Javier and Laine, Forrest}, booktitle = {Proc.~of Robotics: Science and Systems (RSS)}, year = {2022}, url = {https://arxiv.org/abs/2205.00291}, doi = {10.15607/rss.2022.xviii.051}, } -
Inferring Objectives in Continuous Dynamic Games from Noise-Corrupted Partial State Observationspaperwebsitecodevideo
bib
@inproceedings{peters2021rss, title = {Inferring Objectives in Continuous Dynamic Games from Noise-Corrupted Partial State Observations}, author = {Peters, Lasse and Fridovich-Keil, David and Rubies-Royo, Vicen{\c{c}} and Tomlin, Claire J. and Stachniss, Cyrill}, booktitle = {Proc.~of Robotics: Science and Systems (RSS)}, year = {2021}, url = {https://arxiv.org/abs/2106.03611}, doi = {10.15607/rss.2021.xvii.030}, } -
Inference-Based Strategy Alignment for General-Sum Differential Gamespaperwebsitecode
bib
@inproceedings{peters2020ibsa, title = {Inference-Based Strategy Alignment for General-Sum Differential Games}, author = {Peters, Lasse and Fridovich-Keil, David and Tomlin, Claire J. and Sunberg, Zachary N.}, booktitle = {International Conference on Autonomous Agents and Multiagent Systems (AAMAS)}, year = {2020}, url = {https://arxiv.org/abs/2002.04354}, doi = {10.65109/luel2972}, } -
Efficient Iterative Linear-Quadratic Approximations for Nonlinear Multi-Player General-Sum Differential Gamespaperwebsitecodevideo
bib
@inproceedings{fridovich2020ilqgames, title = {Efficient Iterative Linear-Quadratic Approximations for Nonlinear Multi-Player General-Sum Differential Games}, author = {Fridovich-Keil, David and Ratner, Ellis and Peters, Lasse and Dragan, Anca D. and Tomlin, Claire J.}, booktitle = {IEEE International Conference on Robotics and Automation (ICRA)}, year = {2020}, url = {https://arxiv.org/abs/1909.04694}, doi = {10.1109/icra40945.2020.9197129}, pages = {1475--1481}, } -
iLQGames.jl: Rapidly Designing and Solving Differential Games in Juliapaperwebsitecode
bib
@inproceedings{peters2020ilqgamesjl, title = {{iLQGames.jl}: Rapidly Designing and Solving Differential Games in {Julia}}, author = {Peters, Lasse and Sunberg, Zachary N.}, booktitle = {International Workshop on Engineering Multi-Agent Systems (EMAS)}, year = {2020}, url = {https://arxiv.org/abs/2002.10185} } -
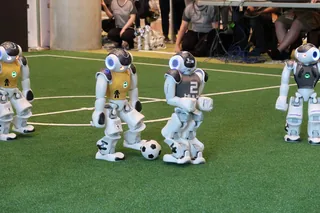 Designing Convolutional Neural Networks Using a Genetic Approach for Ball Detection
Theses & Other
* Equal contribution† Equal advising